Zayyan OS
A hardware-independent brain for companion robots
The question
Can a companion robot decide when to speak with deterministic code — cooldowns, quiet hours, an interruption budget — while the model only ever proposes the words?
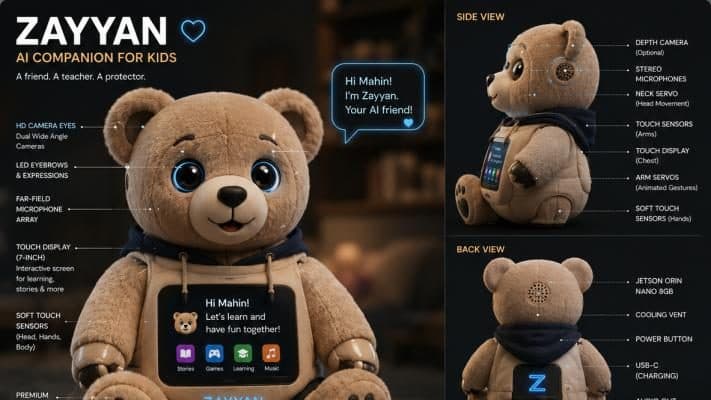
A layered platform for embodied conversational robots. Its first product is a Bangla-speaking teddy bear that helps a child play and a student learn, running on NVIDIA Jetson, with a proactive perception loop, a deterministic behaviour engine, and an LLM that only ever proposes.
- 2
- Personas
- deterministic
- Safety gate
the model never decides; it only supplies the words
What it is
Named after my son, who is also its first user. Applications define a robot experience. Zayyan OS provides the reusable capabilities. Hardware adapters supply physical I/O. No core service may depend on a specific robot, board, sensor, or cloud. The first application is a teddy that sees a person through a USB camera, wakes, greets in Bangla, holds a spoken conversation, and returns to idle.
How it works
- A proactive perception loop: camera → face, gaze, emotion, object, and activity detection with lightweight OpenCV models → a world model → a deterministic behaviour engine that decides whether and when to speak, with cooldowns, quiet hours, and an interruption budget. The LLM proposes the words; code makes the decision.
- Mediated tools: the model can render rich HTML, SVG, and canvas on the robot's screen or request a photo, but every tool call is executed by deterministic code behind a safety gate. Vision is off by default because it sends a picture to the cloud.
- Two personas: a child companion and a student tutor, with automatic switching that defaults to the child-safe persona on any uncertainty.
- Tools exposed over the Model Context Protocol, and external MCP servers consumed, starting with a keyless Bengali-first Wikipedia lookup.
- A browser-based live demo drives the real product code with a web UI instead of the teddy.
Status
Planning and architecture baseline plus the first runnable slice, in simulation and on Jetson. Documentation-first: no subsystem is implemented before its specification and acceptance criteria exist.
Screens and recordings
Connections
Other work that sits in some of the same fields. The overlap is what the map draws.